Porcospino Flex
Catalogs:
Overview
A lightweight crawling robot designed to navigate tight pipes and debris-filled spaces. It takes inspiration from the segmented bodies of millipedes and the spines of porcupines. The design allows the robot to absorb impacts and maneuver passively, without additional motors, during inspections in hazardous industrial environments and confined infrastructure networks.
Tags
- Biomimicry
- Pipe Crawler
Developed by
University of Genoa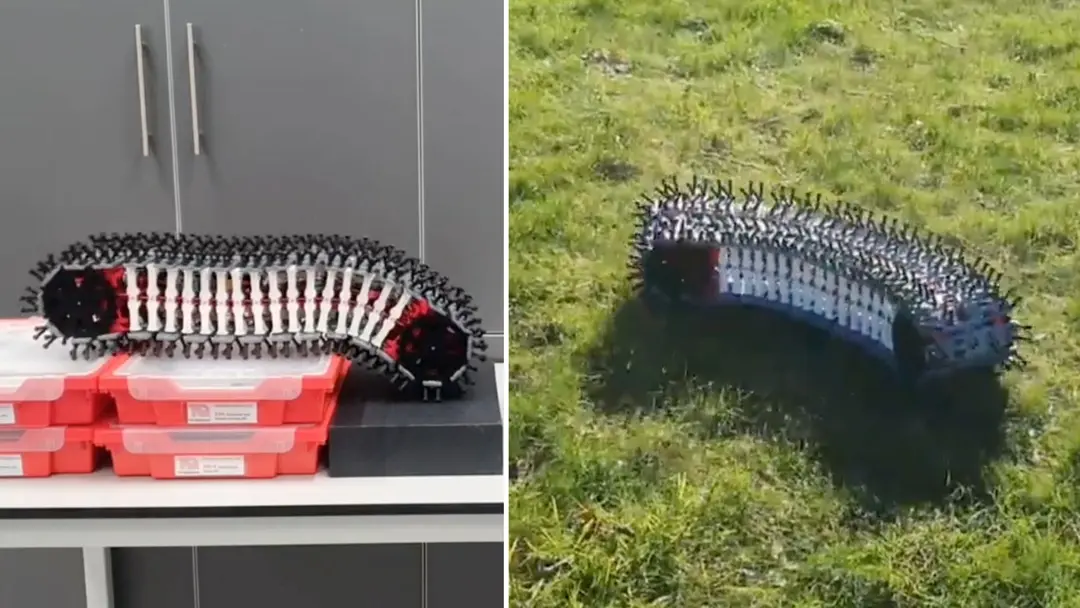

Author: Ian Seed
Created: 2026-10-05 Modified: 2026-10-05
●
Offline