AthenaZero
Catalogs:
Overview
This is a bimanual robot designed for high-speed, human-like dynamic manipulation and athletic tasks (such as throwing objects over 30 m/s, catching and batting over 14 m/s, and playing catch or batting practice in human-to-robot or robot-to-robot setups). It consists of a 1-degree-of-freedom (DoF) torso, two 7-DoF arms, and two 6-DoF underactuated hands (22 actuators across 27 joints).
Tags
- Dual Arm
- Tactile Sensor
Developed by
RAI Institute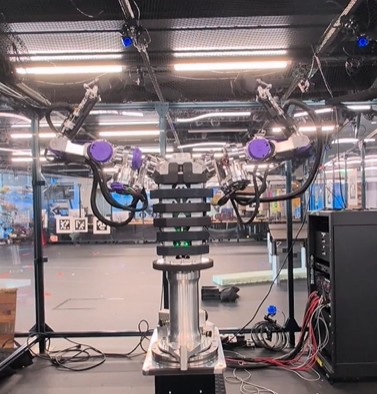

Author: Ian Seed
Created: 2026-10-26 Modified: 2026-10-26
●
Offline